
An open-source simulator to evaluate any lifelong Multi-Agent Path Finding algorithms with real-world kinodynamics and execution uncertainties.
Modular Design#
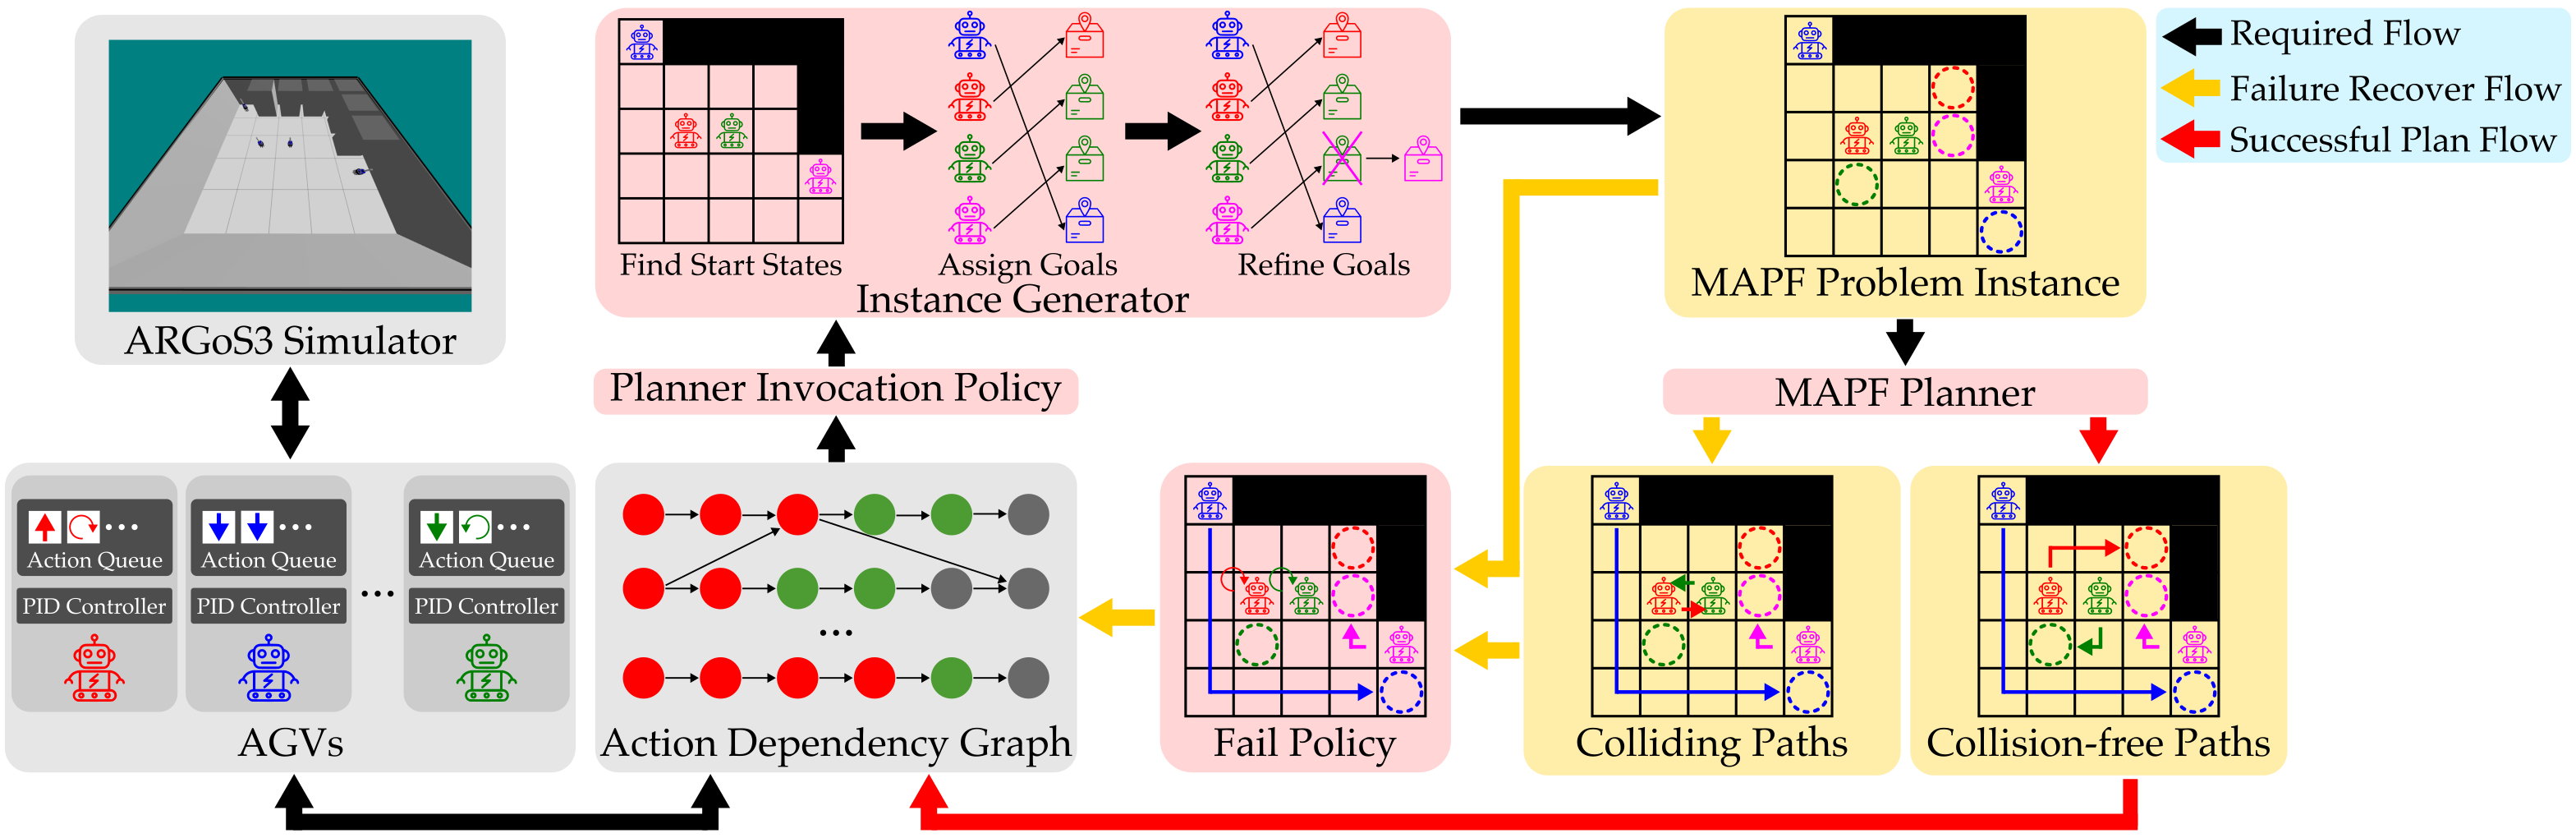
Detailed Architecture of LSMART#
LSMART encapsulates key design choices of a real-world Fleet Management System (FMS) in separate modules. Red boxes highlight the user customizable modules.
Real-world Considerations#
Built on top of SMART [1], we consider realistic AGV kinodynamics by modeling them as differential-drive robots, which can move forward and rotate in place with constraints in maximum velocity and acceleration. This is in contrast to prior works that model AGVs as simple omnidirectional/pebble motion agents. We also simulate real-world execution delays and use Action Dependency Graph (ADG) [2] to ensure collision-free execution of the planned paths.
Insane Scalability#
LSMART is highly scalable in terms of the number of robots and the size of the map. Here we show a simulation of 1000 robots in the warehouse-10-20-10-2-1 map from the MAPF benchmark [3]. We use PIBT [4] as the underlying MAPF planner and plan windowed paths every 1 simulation second. The simulation runs for 600 simulation seconds and takes 268 seconds to finish with a AMD Ryzen 9 9950X 16-Core Processor.
Tutorial#
The video starts at the LSMART tutorial (1:52:15). Follow along with the tutorial slides.
References#
[1] Yan, J.; Li, Z.; Kang, W.; Zheng, K.; Zhang, Y.; Chen, Z.; Zhang, Y.; Harabor, D.; Smith, S. F.; and Li, J. 2025. Advancing MAPF towards the Real World: A Scalable Multi-Agent Realistic Testbed (SMART). ArXiv, abs/2503.04798.
[2] Hönig, W.; Kiesel, S.; Tinka, A.; Durham, J. W.; and Ayanian, N. 2019. Persistent and Robust Execution of MAPF Schedules in Warehouses. IEEE Robotics and Automation Letters, 4: 1125-1131.
[3] Stern, R.; Sturtevant, N. R.; Felner, A.; Koenig, S.; Ma, H.; Walker, T. T.; Li, J.; Atzmon, D.; Cohen, L.; Kumar, T. K. S.; Barták, R.; and Boyarski, E. 2019. Multi-Agent Pathfinding: Definitions, Variants, and Benchmarks. In Proceedings of the International Symposium on Combinatorial Search (SoCS), 151-159.
[4] Okumura, K.; Machida, M.; Défago, X.; and Tamura, Y. 2019. Priority Inheritance with Backtracking for Iterative Multi-agent Path Finding. In Proceedings of the International Joint Conference on Artificial Intelligence (IJCAI), 535-542.
Paper and Citation#
@article{YanAndZhang2026LSMART,
    author    = {Jingtian Yan, Yulun Zhang, Zhenting Liu, Han Zhang, He Jiang, Jingkai Chen, Stephen F. Smith and Jiaoyang Li},
    title     = {Lifelong Scalable Multi-Agent Realistic Testbed and A Comprehensive Study on Design Choices in Lifelong AGV Fleet Management Systems},
    journal   = {ArXiv},
    volume    = {abs/2602.15721},
    year      = {2026}
}